VACUFORCE SQUID® | MODULAR VACUUM EOAT
Vacuforce Squid® VFSQLT3030-OR — 12" × 12" Open-Orifice Vacuum Gripper
The VFSQLT3030-OR is a 288 × 288mm (nominal 12" × 12") modular robotic vacuum end-of-arm tool with 36 published cup-mounting positions and a restricted-orifice cup-port configuration. It is designed for carton handling, palletizing, packaging lines and multi-point automated picking where the vacuum layout must match the product.
How this configuration works
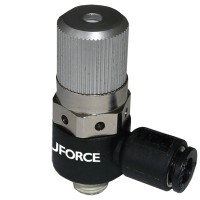
Restricted orifice fittings limit the airflow through uncovered cup positions. The vacuum source must be selected to accommodate the resulting controlled leakage while sealed cups maintain sufficient vacuum.
This model designates the gripper body and vacuum-control configuration. The cup-port count describes available mounting positions; it is not a statement that every position is supplied with a suction cup. Select the final cup type and quantity for the actual product geometry.
Technical Specifications
| Specification | Details |
|---|---|
| Vacuforce model | VFSQLT3030-OR |
| Product family | The Squid® modular vacuum gripper / robotic EOAT |
| Nominal footprint | 12" × 12" (actual 288 × 288mm) |
| Published cup-mounting positions | 36 |
| Vacuum-control configuration | Restricted orifice (OR) |
| Cup specification | Application-selected; cups not identified by this SKU suffix |
| Base-body vacuum port positions | Three potential G3/4 vacuum port positions |
| Vacuum source | Application-selected pump, regenerative blower or compressed-air Venturi generator |
| Manufacturer reference assembly weight | 5.5lb (2.5kg) (catalogue example; equipped weight varies) |
| Custom tooling options | Application-specific mounting, cup layout and vacuum zoning |
| Design information | Vacuforce Squid® catalogue and engineering drawings |
Why The Squid® Works for Mixed-Size Picks
A conventional fixed cup pattern can lose vacuum when a smaller carton covers only part of the tool. The Squid® platform can manage these open pickup points through restricted orifices or self-closing valves, depending on the expected leakage and vacuum source. Actual holding performance must be checked under the intended load, acceleration and surface conditions.
Choose the right air-leakage strategy
Controls leakage through uncovered cup ports; the vacuum source must handle that leakage.
Isolate open cup positions as airflow triggers the adjustable valves, preserving vacuum in sealed pickup zones.
Typical Applications
Robotic case picking and palletizing; end-of-line carton handling; corrugated packaging; slip sheets and panels; plastic-wrapped bales; multi-size pick-and-place; custom gantry or robot EOAT with distributed suction points.
Frequently Asked Questions
What size is the VFSQLT3030-OR gripper?
How many vacuum cup locations does VFSQLT3030-OR provide?
What is the difference between the OR and VFSC versions?
Can the same gripper pick cartons of different sizes?
Does this assembly include a vacuum generator?
Is the published cup count a rated lifting capacity?
Can the robot mounting pattern and cup spacing be customized?
Which details should I provide for selection?
Need a different cup pattern or robot mounting interface? Share your product dimensions, surface, payload, vacuum source and robot details with Vacuforce.
Explore The Squid® PlatformShips from Indianapolis, USA
- Stock: 1